Cable-Driven Parallel Robot
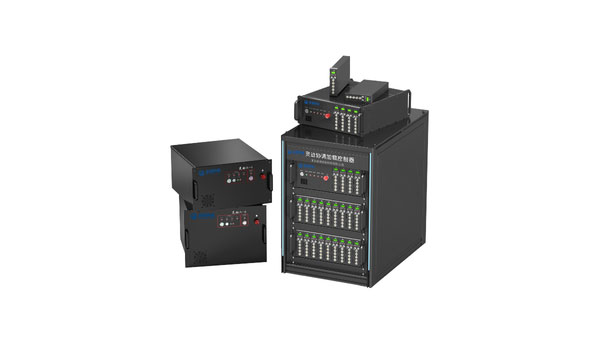
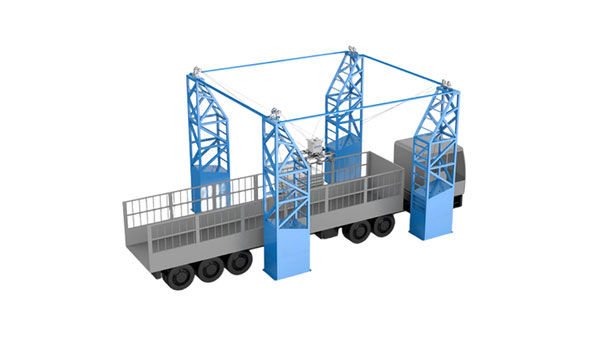
Cable-Driven Parallel Robots can fully replace manual labor to accomplish automated loading and unloading of bagged goods. A single unit achieves an automated handling capacity of 1200-2400 bags per hour, boosting efficiency by 300%-500% compared with manual operations. It supports stable 24/7 non-stop operation for sound economic benefits. Featuring flexible layout and low maintenance costs, Cable-Driven Parallel Robots adapt to various site conditions and vehicle types. They eliminate manual handling errors and work-related injuries. Widely applied for bagged products such as chemical fertilizers, salt, feed, and PVC materials, they have earned consistent positive feedback from customers. As preferred equipment for automated bag-goods loading and unloading, they facilitate the construction of intelligent factories.
- Footprint: 10 M×8 M×7 M (customizable)
- Working Envelope: 8 M×6 M×4.5 M (customizable)
- Basic Function: Loading and unloading of bagged goods
- Average Power Consumption: Approx. 20 kW
- Working Efficiency: 1200-2400 bags per hour
- Service Life: 10 years
- Optional Modules: WMS interface module, WCS interface module, goods-category identification module
- Cargo Type: 20 KG-70 KG bagged products
Key Technologies
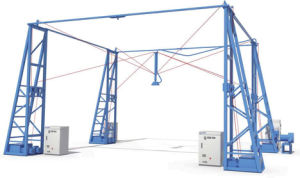
Cable-Driven Parallel Robot
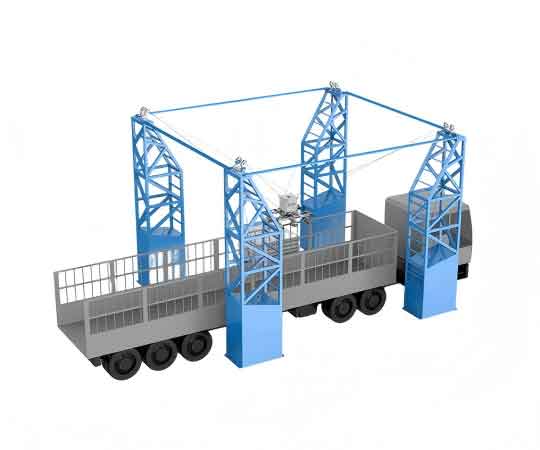
Leveraging its years of profound expertise and widely adopted hybrid force-position control technology in the aerospace industry, Pinchuang Technology has developed the cable-driven parallel robot. The end moving platform is connected to the fixed platform via flexible cables, and its spatial position and posture are precisely controlled by real-time adjustment of cable length and tension. Adopting aerospace-grade force control technology, the robot features an ultra-large working envelope, high precision and superior safety, making it widely applicable in industrial, scientific research and educational fields.
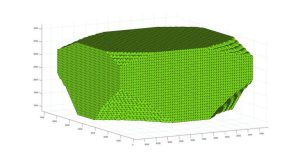
Workspace Planning
The cable-driven parallel robot adopts workspace analysis to ensure that the suction cups or grippers can accurately reach designated positions within the defined operating range. As a core customized technology designed according to actual site conditions, workspace planning is one of Pinchuang Technology’s profound technical strengths with rich practical implementation experience.
Intelligent Visual Recognition
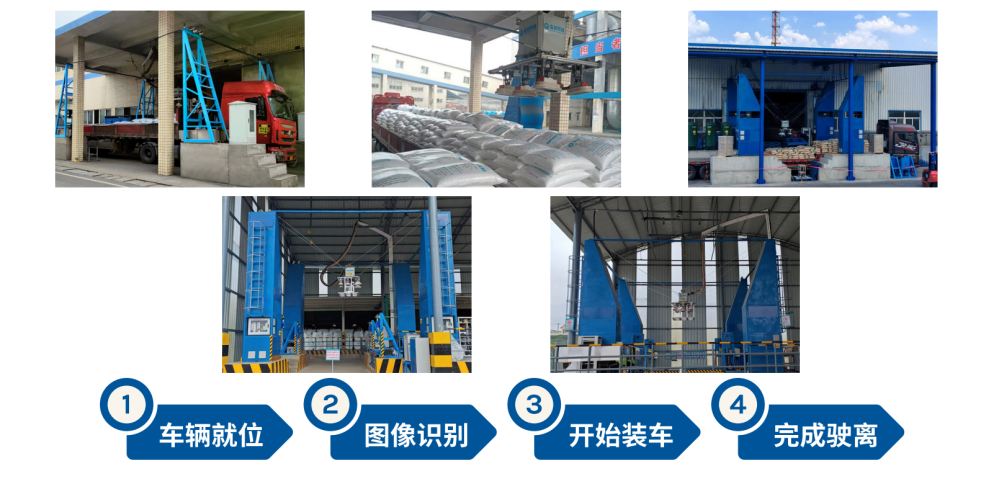
Equipped with high-definition cameras and LiDAR, the intelligent visual recognition system rapidly captures feature information of bagged products. Powered by artificial intelligence algorithms, the AI-based visual system delivers millimeter-level positioning accuracy and a recognition accuracy rate of 99.5%, guiding the cable-driven parallel robot to perform precise cargo loading and unloading. Pinchuang Technology holds multiple patents for this system and has developed a series of dedicated image processing products to adapt to diverse operating scenarios.
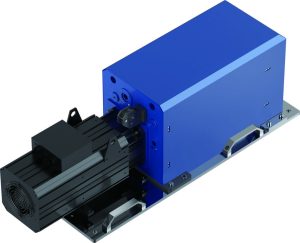
High-Precision Servo Drum
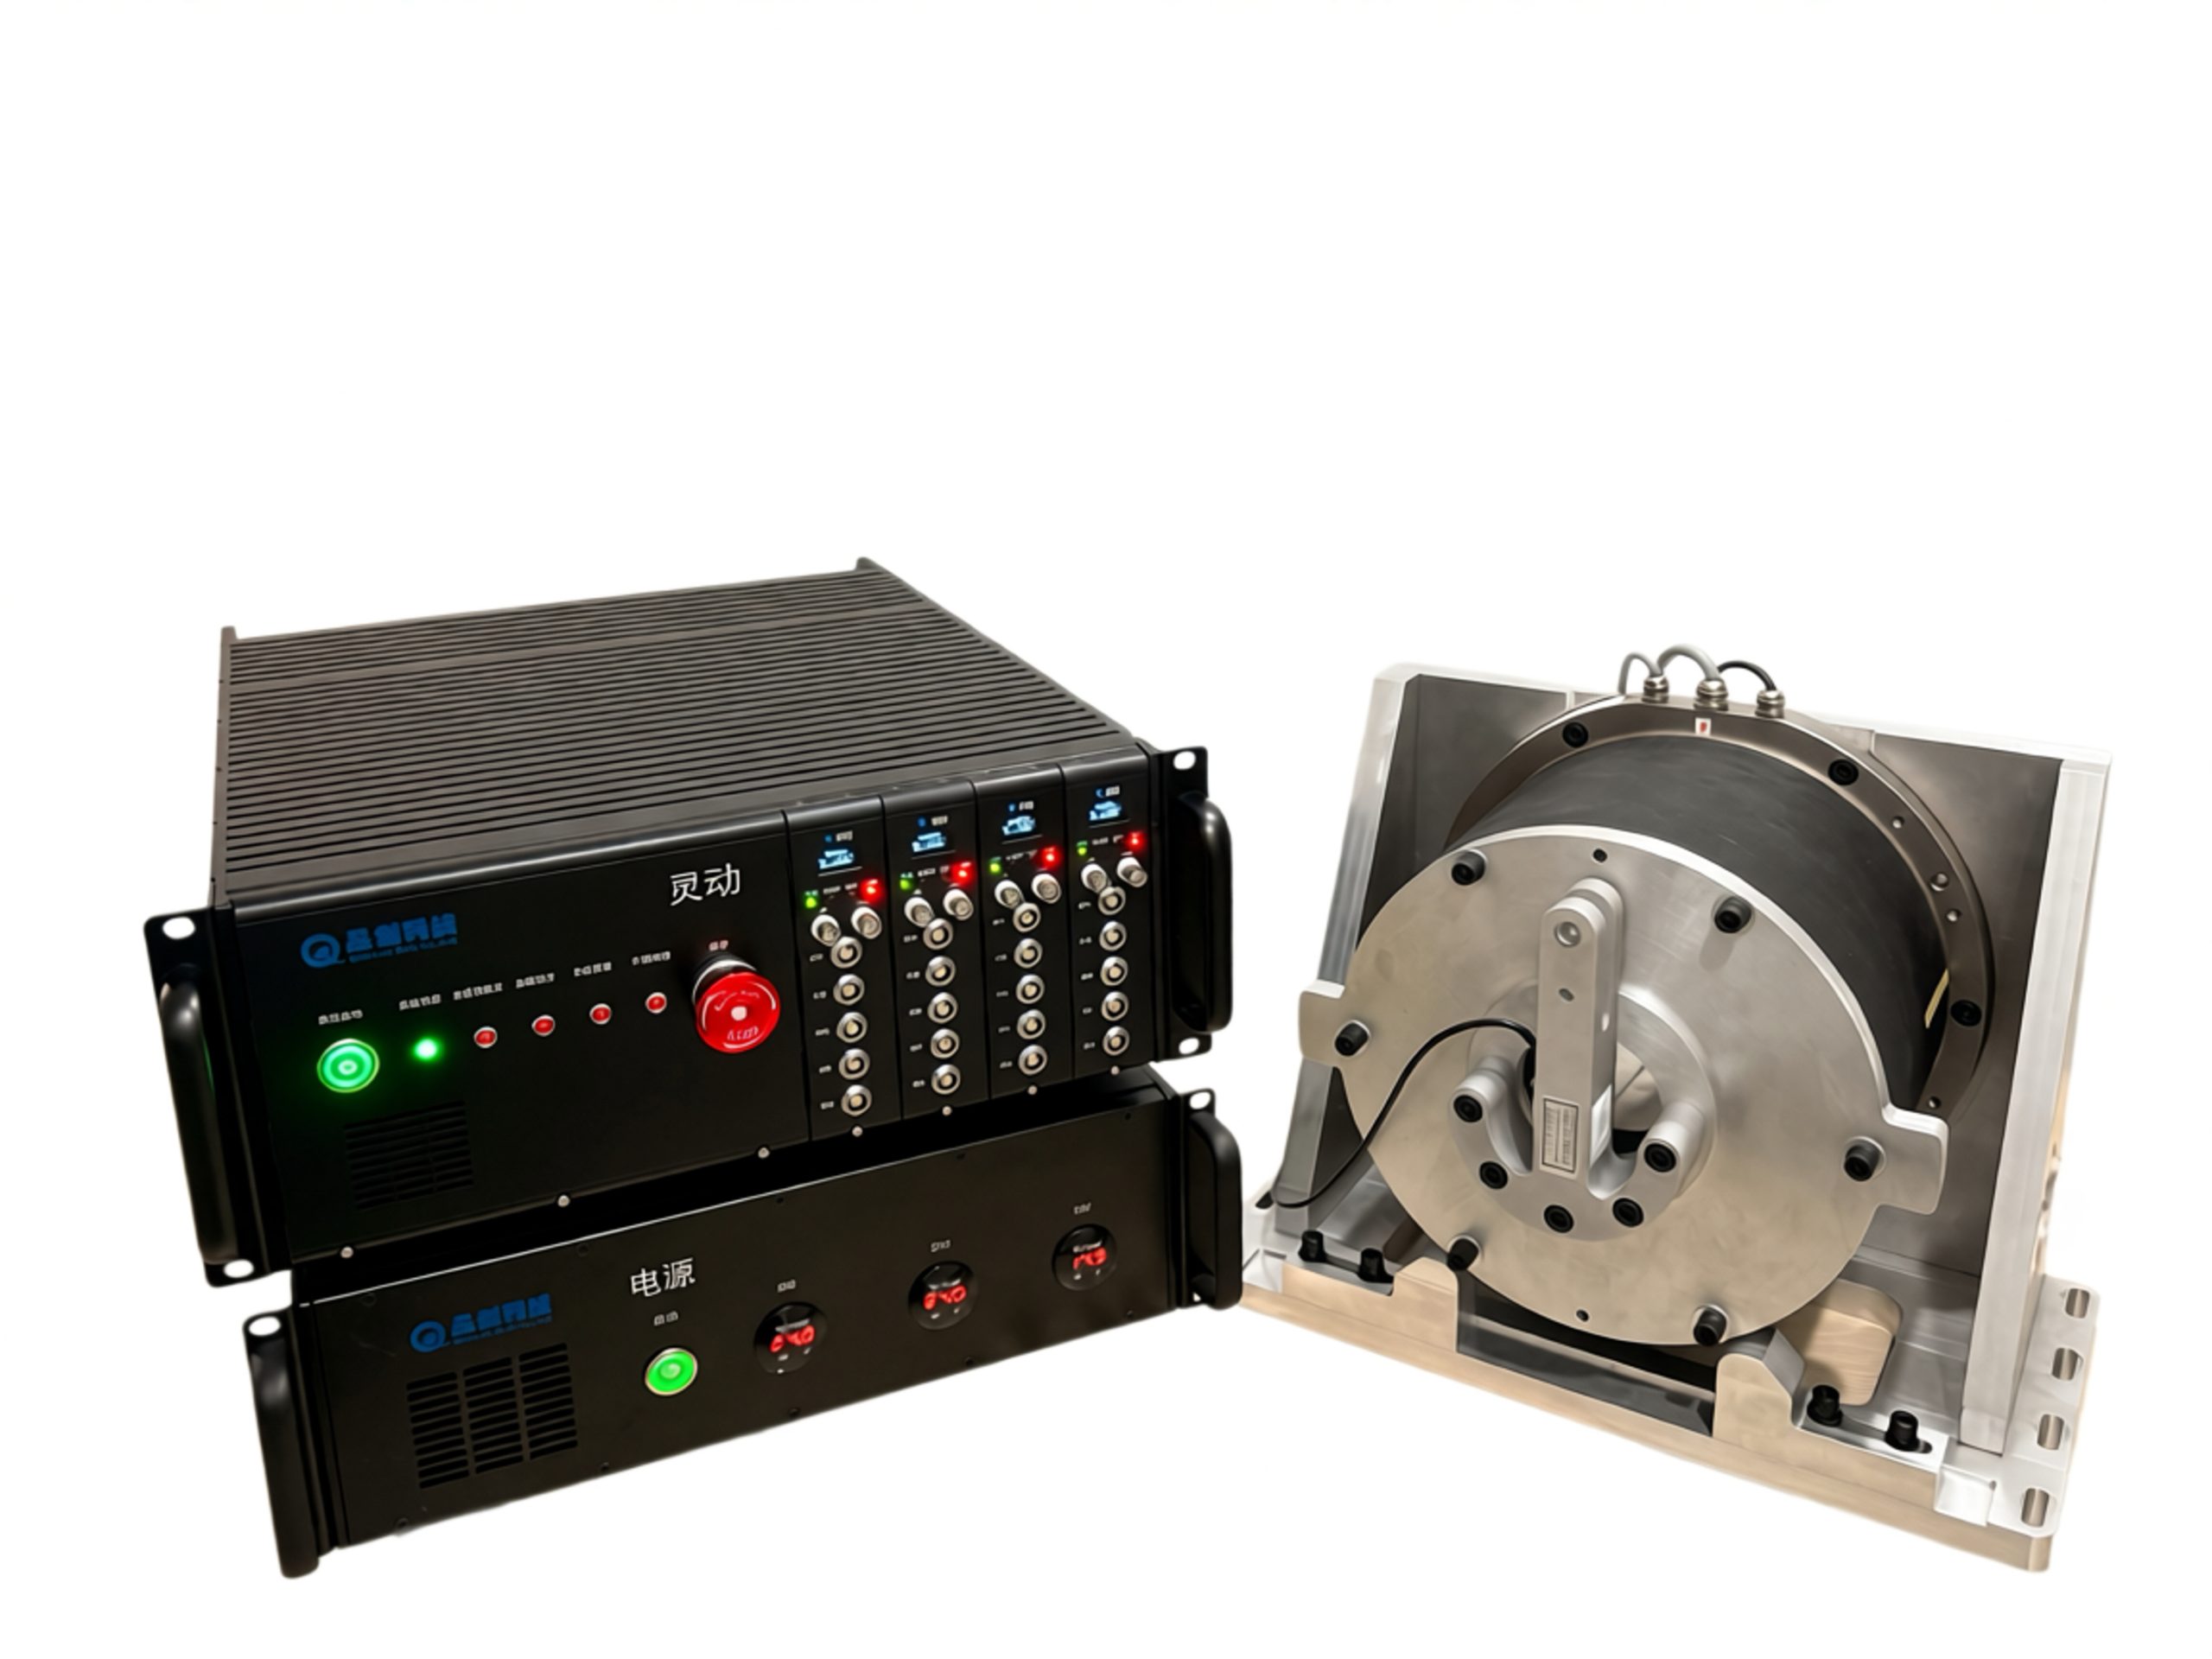
The high-precision servo drum serves as the core component that enables the cable-driven parallel robot to place cargo accurately at target positions. Based on independently developed precision servo systems, the drum achieves precise closed-loop control of cable length and cable tension.
Advantage 1: No Stacker Destacker Required
Adopting an integrated loading and unloading design, the cable-driven parallel robot independently completes the entire process from pallet unstacking to truck loading, realizing seamless connection between destacking and loading operations. It improves the overall handling efficiency by more than 30%, while significantly reducing customers’ equipment investment costs and site occupation space.
Advantage 2: No On-board Manual Operation Required
The robot performs full-automatic loading and unloading throughout the entire workflow, eliminating the need for operators to work inside truck carriages. Supported by intelligent visual positioning and hybrid force-position control technology, it delivers high-precision operations and avoids potential safety hazards caused by manual onboard work, building a safe and reliable operating environment for enterprises.
Advantage 3: Minimal Site Renovation
The cable-driven parallel robot requires minimal infrastructure and site modification. It can be rapidly deployed with simple renovations on standard loading and unloading platforms without large-scale construction. This reduces site renovation investment by over 80% and greatly cuts construction costs and project cycles.
Advantage 4: Convenient Subsequent Maintenance
Featuring a modular structure, the robot only incurs one-third of the annual maintenance cost of truss robots. It requires no professional maintenance team, and daily upkeep can be completed by ordinary technical personnel. Only regular power cable inspection and rotating part lubrication are needed, reducing maintenance workload by more than 60%.